

TRON 2
Collection
Models, datasets and tools for TRON 2, the LimX Dynamics multi-form embodied robot for loco-manipulation. • 2 items • Updated
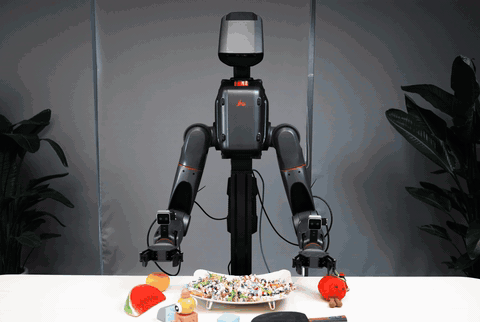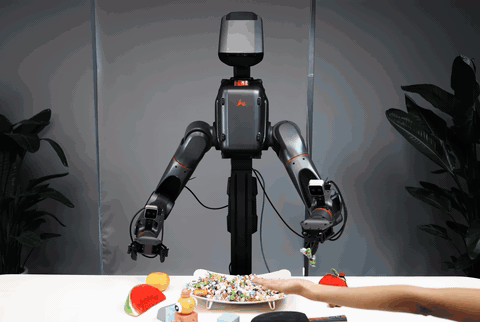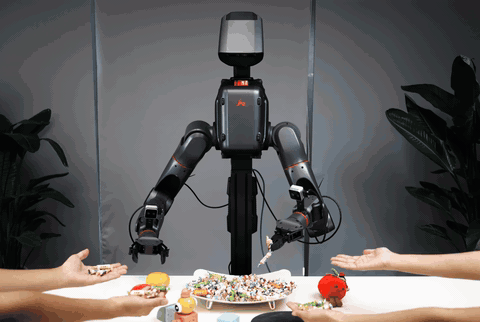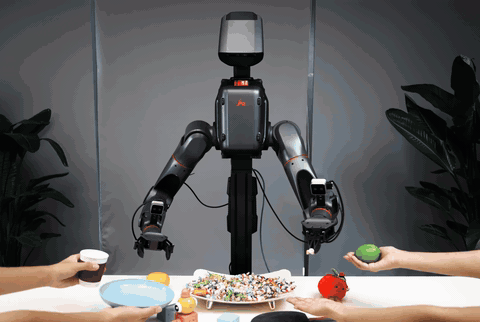
Deployment-oriented Pi0.5 checkpoints for LimX TRON 2 manipulation, fine-tuned with OpenPI and integrated with TRON 2 policy modules. They work with the Pi0 / Pi0.5 policy-serving pipeline and the real-robot clients in tron2_openpi.
| Candy handover | Cloth folding |
|---|---|
 |
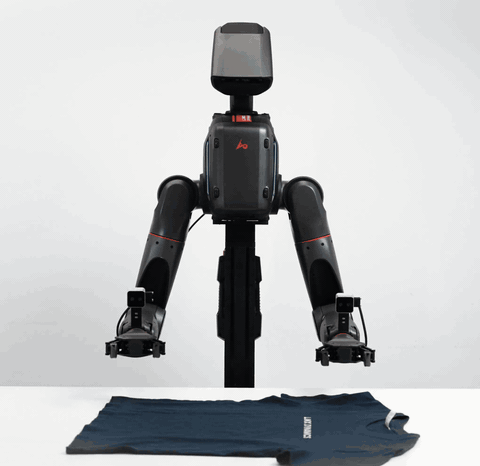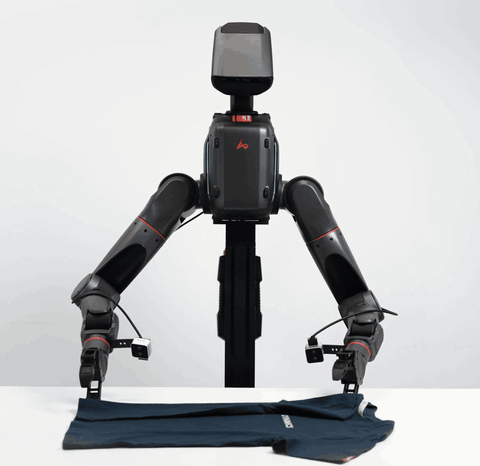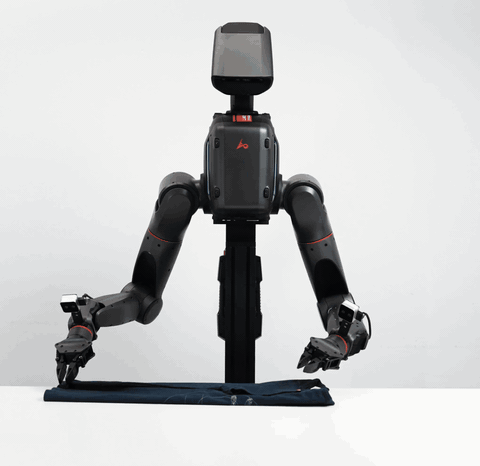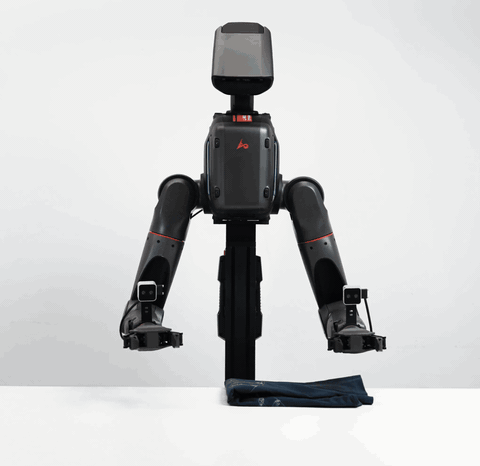 |
Higher-quality MP4 versions: candy_handover.mp4 · cloth_fold.mp4
| Task | Checkpoint folder | Norm stats repo_id |
|---|---|---|
| Candy | pi05_tron2_candy/candy_h30_rtc_25000 |
input |
| Cloth | pi05_tron2_cloth/cloth_h30_rtc_74999 |
input |
| Sort | pi05_tron2_sort/sort_h50_rtc_30000 |
input |
| Organize the Desktop | pi05_tron2_desktop/desktop_h30_rtc_20000 |
input |
| Bean Pouring | pi05_tron2_beans/beans_h30_rtc_15000 |
input |
| Clean the Floor (chassis) | pi05_tron2_chassis/chassis_h30_rtc_15000/14999 |
chassis270 |
pi05_tron2_banana is an additional checkpoint set without a public deploy profile.
tron2_openpi and tron2_env side by side, following the installation guide.hf download limxdynamics/tron2-openpi-models --include "pi05_tron2_candy/*" --local-dir ./checkpoints
policy.checkpoint_dir to the downloaded step folder and policy.repo_id to the norm stats folder in the table above.uv run scripts/serve_policy.py --profile configs/deploy/candy_server.yaml
uv run examples/tron2/pi_client_rtc.py --profile configs/deploy/candy_client.yaml
To fine-tune on your own task, see the training section of the tron2_openpi README.
These checkpoints drive a physical robot. Start from the robot's initial state, keep the workspace in front of the robot clear (both arms will move), and run only with a trained operator present and the emergency stop within reach.
The tron2_openpi code is released under Apache 2.0. The checkpoints build on OpenPI models derived from PaliGemma, so use of the model weights is also subject to the Gemma terms; see the license files in tron2_openpi.